開発実績Work開發實績
ロボット開発に必要な専門領域をすべて社内チームでカバーし、分野の境目で止まらない開発を行います。Every discipline a robot needs sits inside one team, so development never stalls at the boundary between specialities.機器人開發所需的各專業領域都在團隊內,開發不會卡在專業之間的交界。
車輪脚ロボットWheel-legged robot輪足機器人
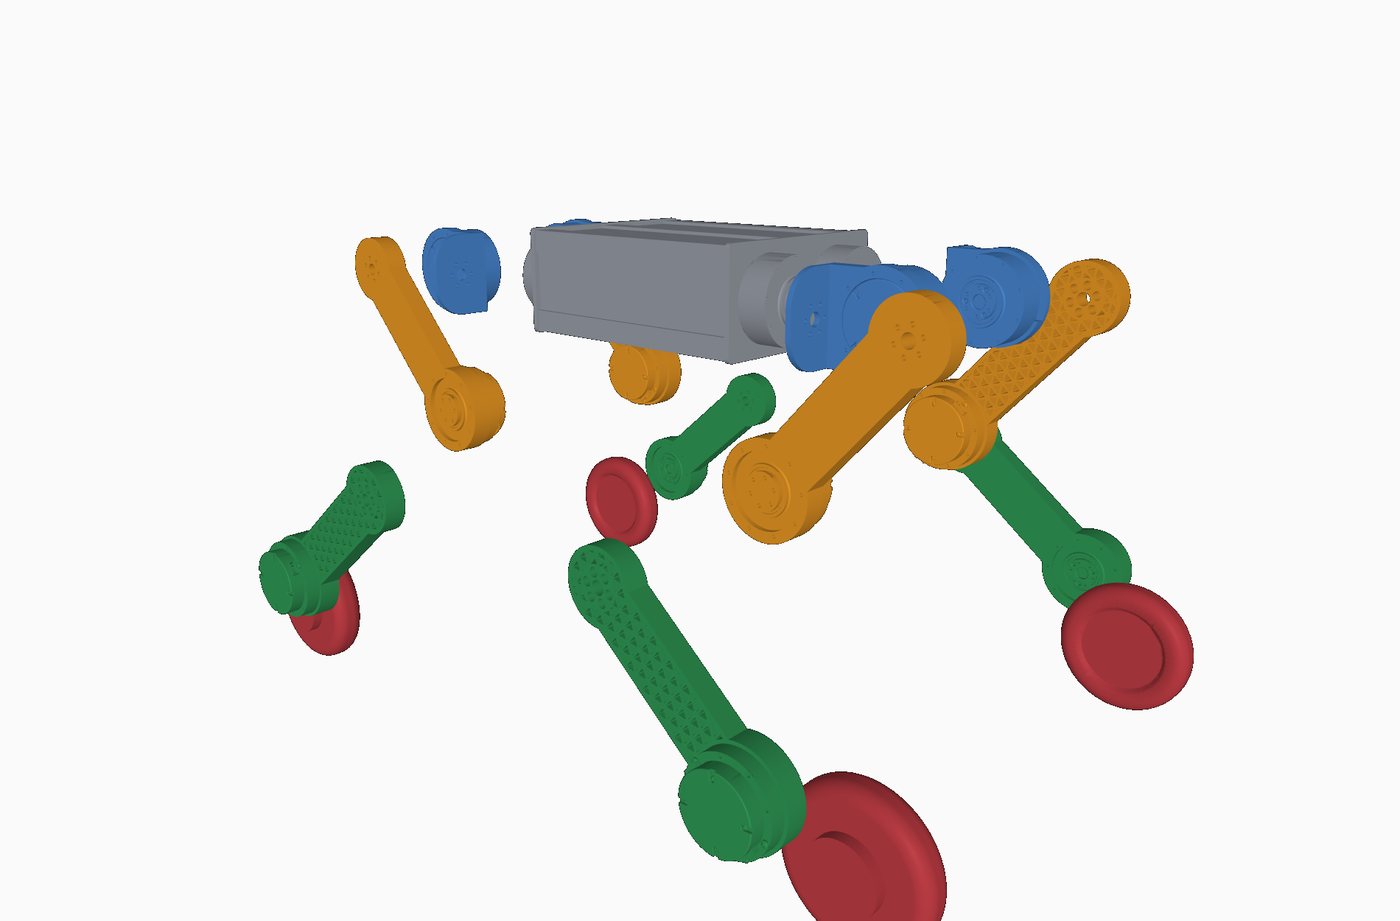
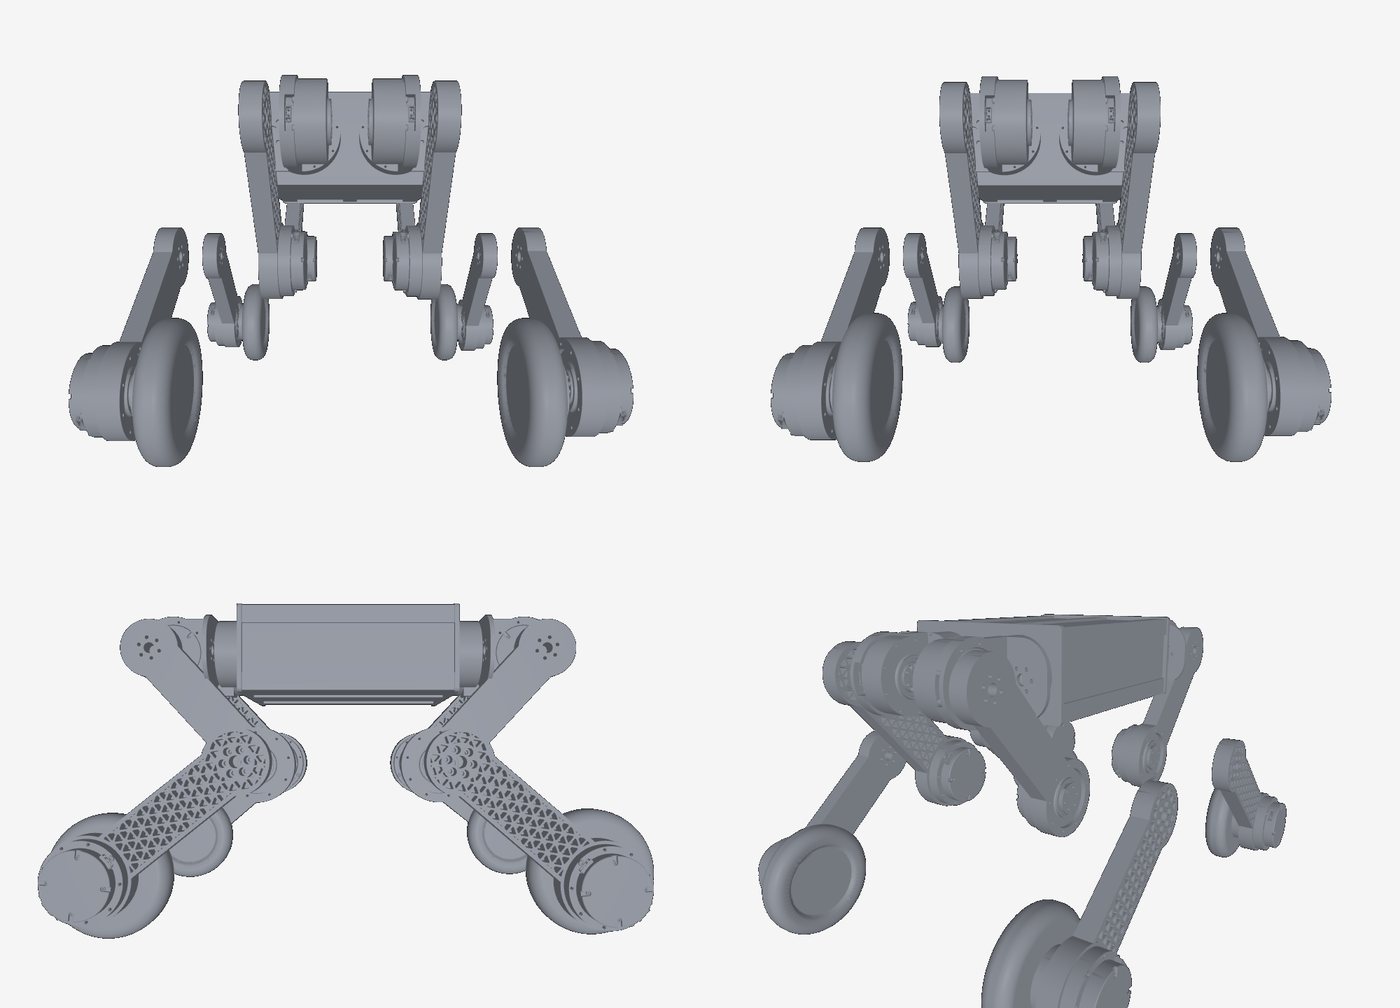
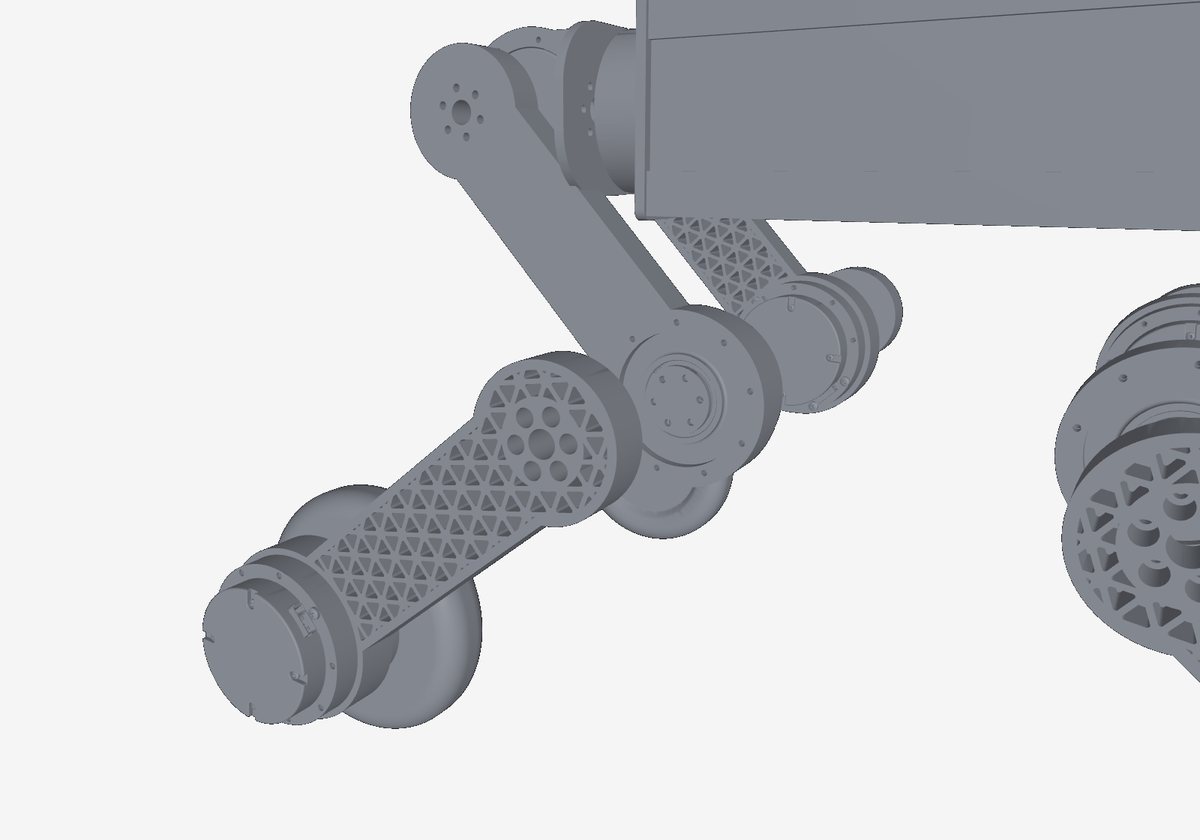
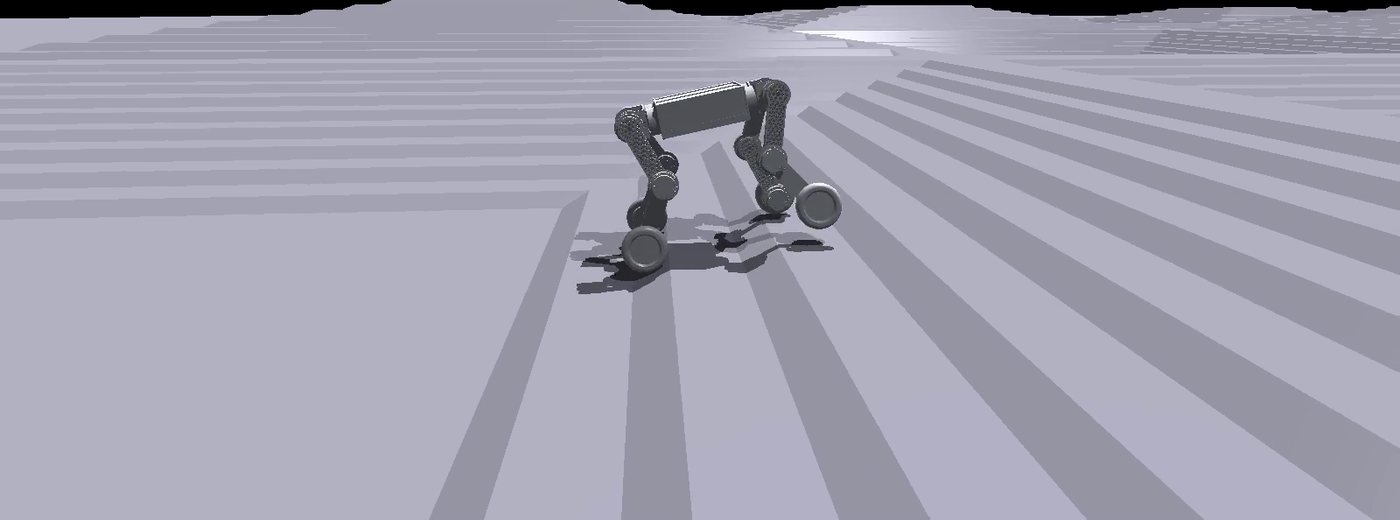
股関節の開閉・股関節・膝・車輪に計16軸の関節を持つ四足の車輪脚ロボット。機構・アクチュエータ選定・電装から、シミュレーションでの強化学習、実機への移植、キャリブレーションまでを一貫して開発しました。膝は同軸配置、足先に車輪モーターを置き、歩行と走行を切り替えます。
A wheel-legged quadruped with 16 joints (hip abduction, hip, knee and wheel). We developed it end to end: mechanics, actuator selection and electronics, reinforcement learning in simulation, transfer to the real machine and calibration. Coaxial knees and wheel motors at the feet let it switch between walking and rolling.
具備髖外展、髖、膝、輪共 16 個關節的四足輪足機器人。從機構、致動器選型與電控,到模擬中的強化學習、移植實機與校準,一路自行開發。膝關節同軸配置、足端設輪馬達,可在行走與滾動之間切換。
- 関節 16 軸(股関節の開閉・股関節・膝・車輪)
- シミュレーションで学習した歩行・階段昇降
- 実機キャリブレーション受入精度 1.28°
- 納品機でのシミュレーションと実機の差 2–4 mm
- 16 joints (hip abduction, hip, knee, wheel)
- Walking and stair-climbing learned in simulation
- On-robot calibration accepted at 1.28°
- Sim-to-real gap of 2–4 mm on a delivered machine
- 16 個關節(髖外展、髖、膝、輪)
- 在模擬中學會行走與上下樓梯
- 實機校準驗收精度 1.28°
- 交付機的模擬與實機差距 2–4 mm
関節アクチュエータJoint actuators關節致動器
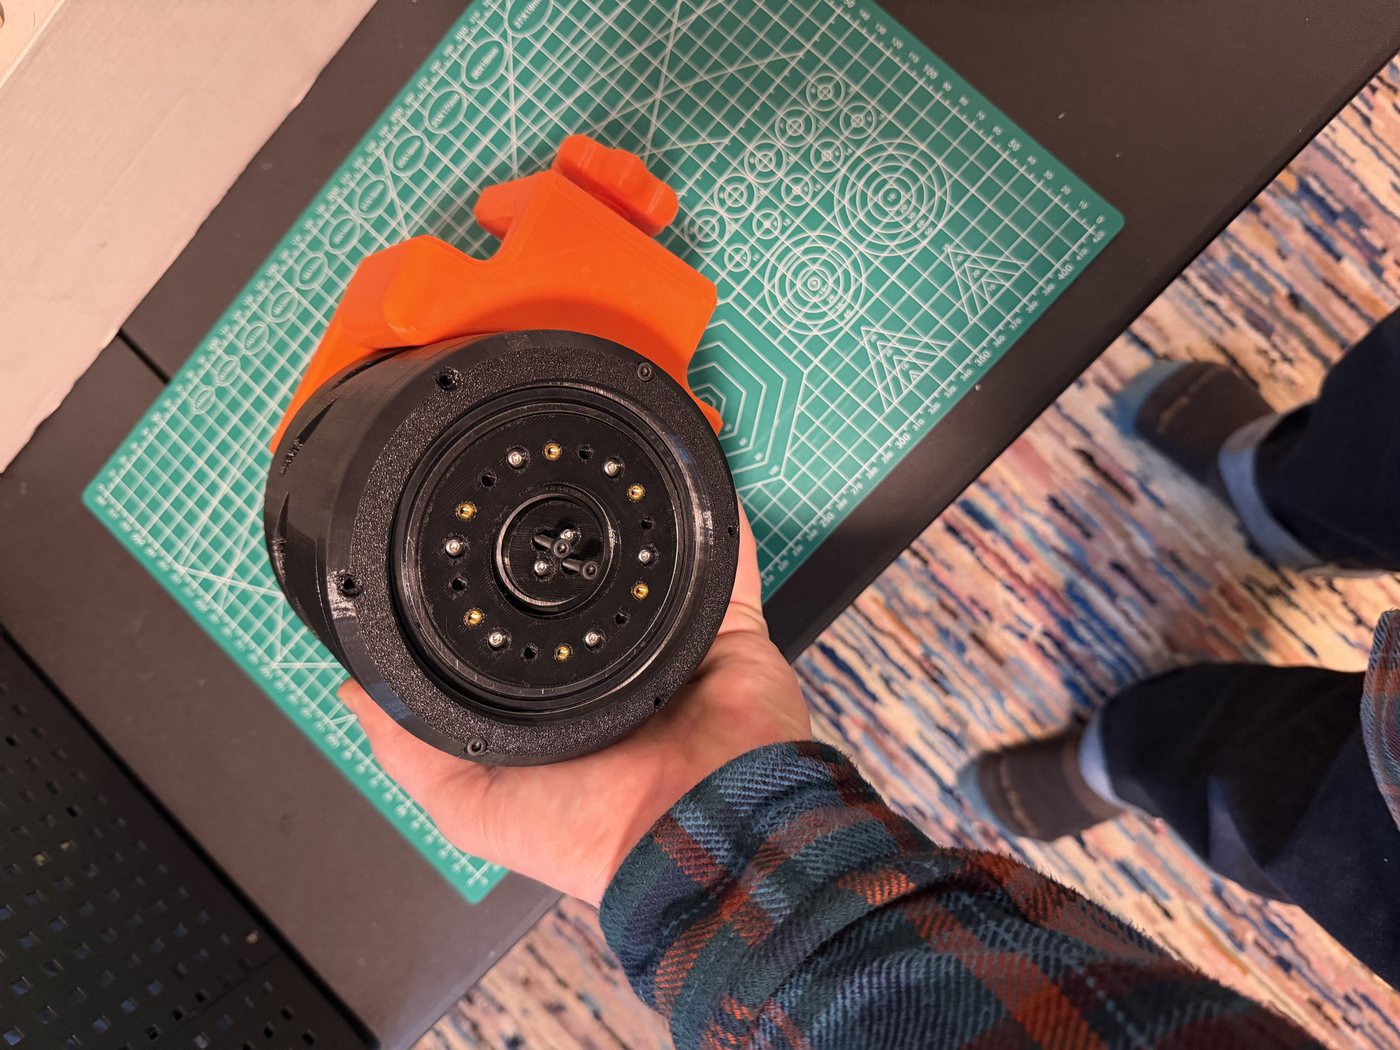
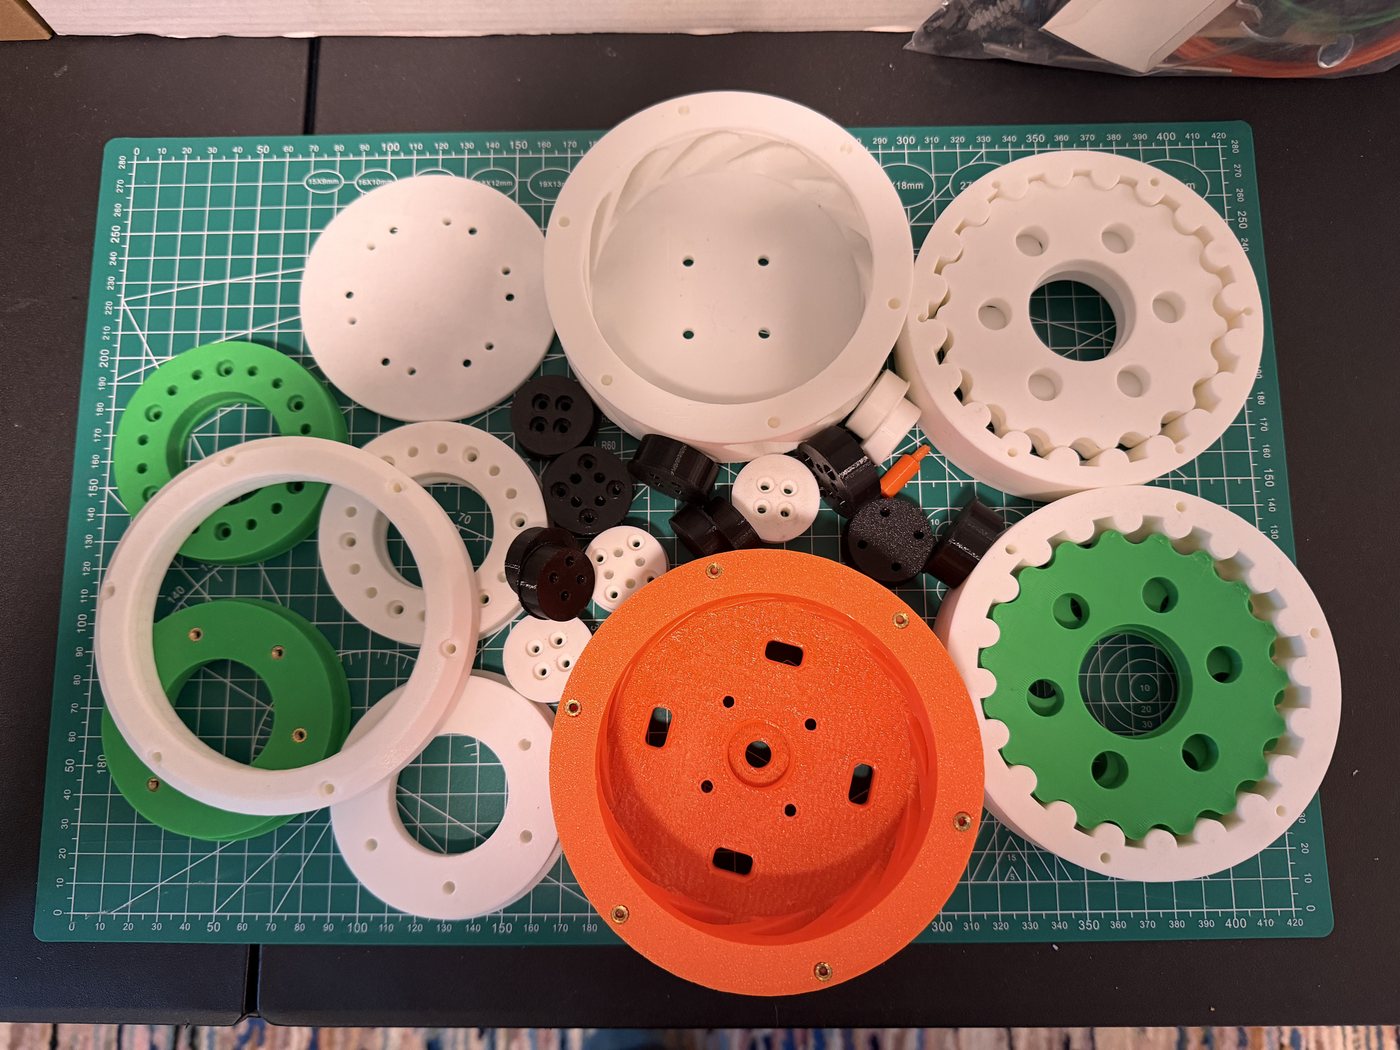
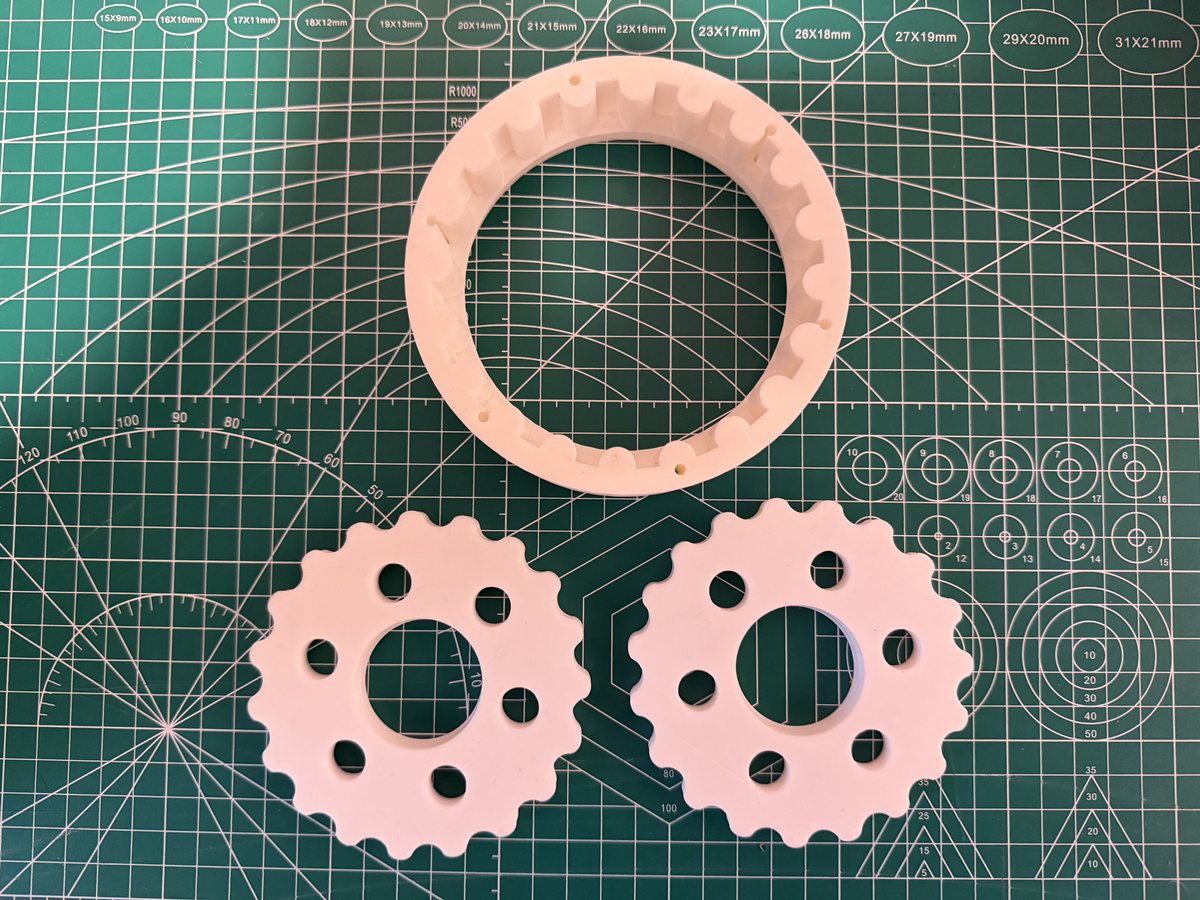
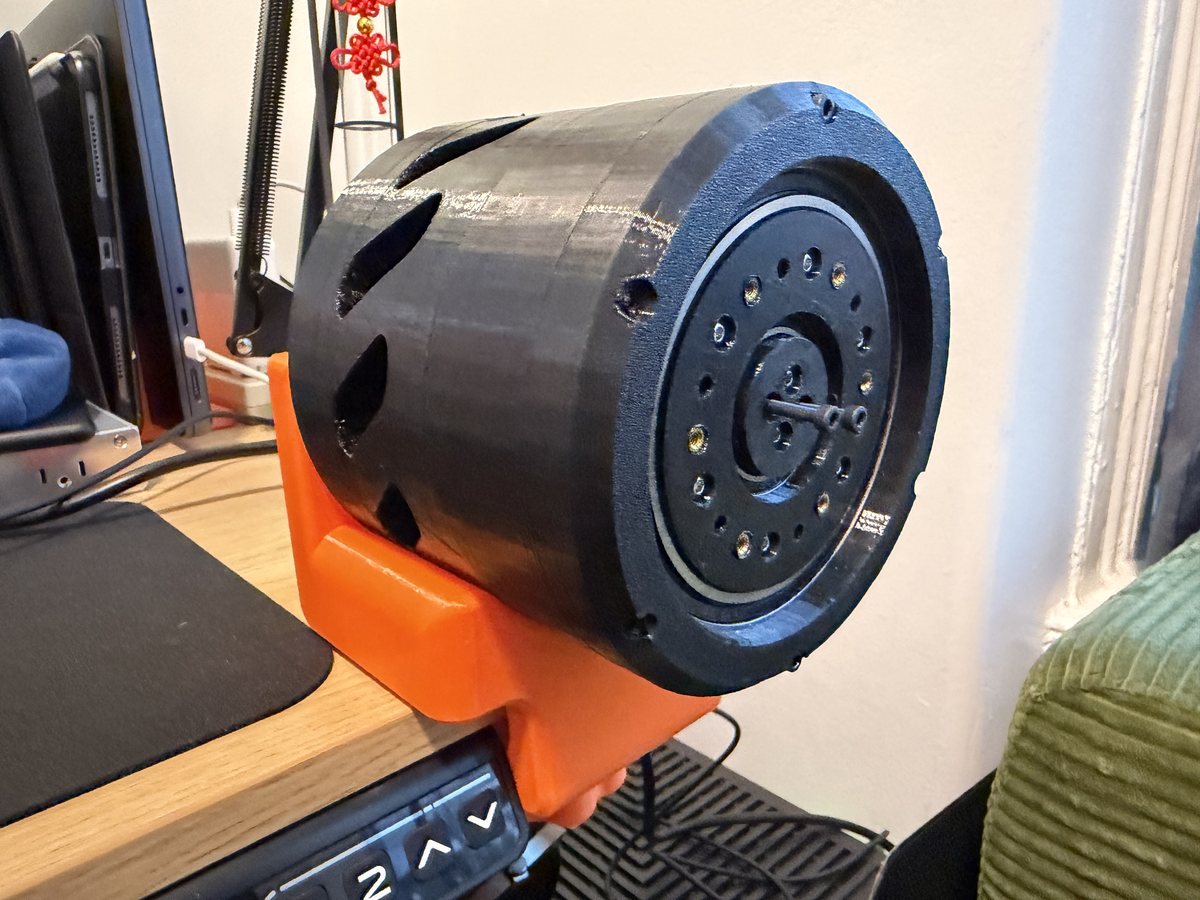
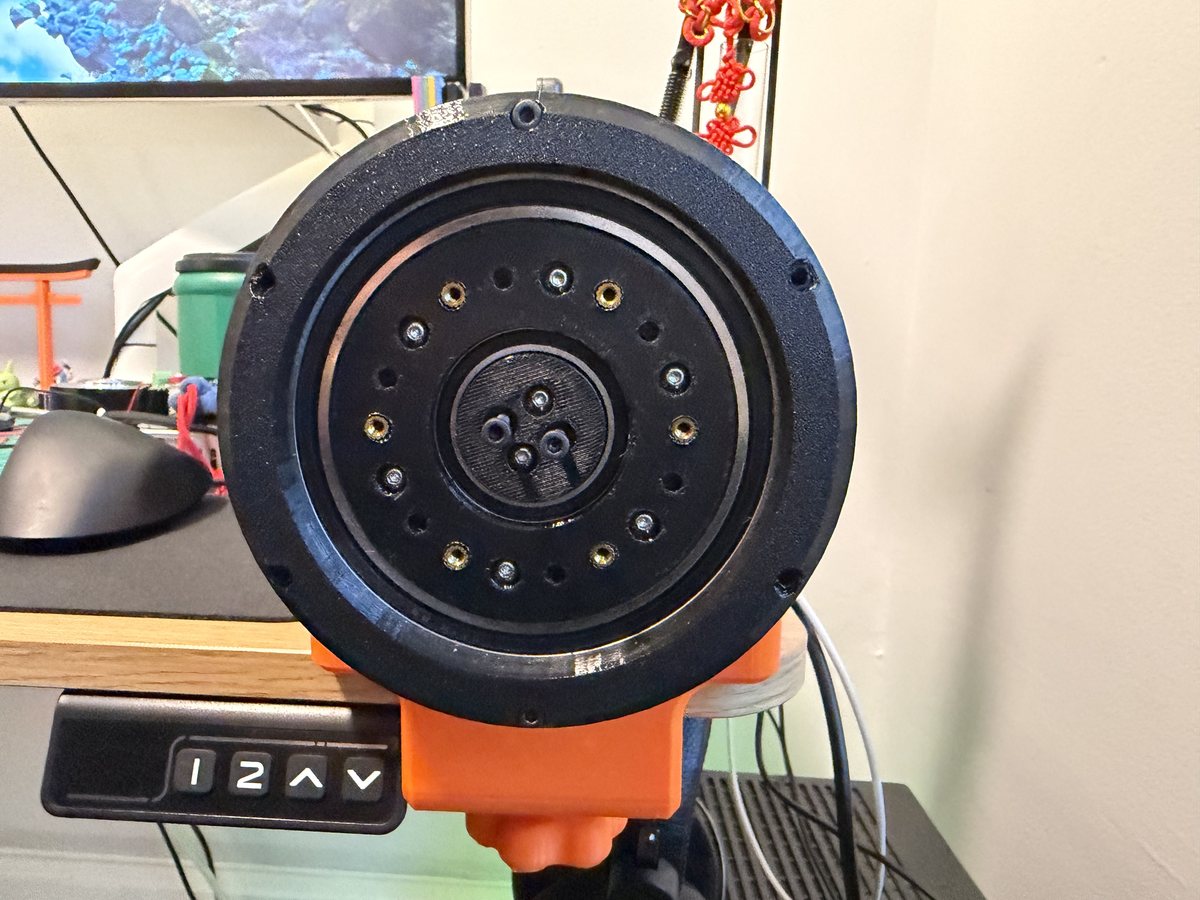
ロボットの性能は関節で決まります。必要なトルクと速度から減速比とモーターを逆算し、市販アクチュエータの採用と自社試作を使い分けます。写真はオープンソース設計をもとに社内で製作した 3D プリント・サイクロイド減速アクチュエータで、減速比 15:1 を実測しています。
A robot is only as good as its joints. We work back from required torque and speed to the reduction ratio and motor, and choose between off-the-shelf actuators and in-house prototypes. Shown: a 3D-printed cycloidal actuator we built in-house from an open-source design, with a measured 15:1 reduction.
機器人的性能取決於關節。我們由所需扭矩與轉速反推減速比與馬達,在市售致動器與自家試作之間取捨。照片是以開源設計為基礎、在團隊內製作的 3D 列印擺線減速致動器,實測減速比 15:1。
採用アクチュエータActuators we deploy採用的致動器
車輪脚ロボットには RobStride 社の一体型関節アクチュエータ(RS02・RS04)を採用し、摩擦・遅れ・トルク係数を実測してシミュレーションに反映しています。
Our wheel-legged robot uses RobStride integrated joint actuators (RS02, RS04); we measure their friction, latency and torque constant and feed them back into simulation.
輪足機器人採用 RobStride 的一體化關節致動器(RS02、RS04),並實測摩擦、延遲與扭矩係數,回饋到模擬中。
ロボット開発のご相談はお気軽にPlanning a robot? Let’s talk.有機器人開發需求,歡迎洽詢
構想段階のご相談から、試作・量産設計・納品後の保守まで。日本語・英語・中国語で対応します。From an early idea to prototyping, production design and post-delivery support — in Japanese, English or Chinese.從構想階段的討論,到試作、量產設計與交付後維護;日文、英文、中文皆可。